<br />

The intent of this notebook is to help TFP 0.11.0 "come to life" via some small snippets - little demos of things you can achieve with TFP.

|---|---|---|---|
| [![](https://www.tensorflow.org/images/tf_logo_32px.png)View on TensorFlow.org](https://www.tensorflow.org/probability/examples/TFP_Release_Notebook_0_11_0) | [![](https://www.tensorflow.org/images/colab_logo_32px.png)Run in Google Colab](https://colab.research.google.com/github/tensorflow/probability/blob/main/tensorflow_probability/examples/jupyter_notebooks/TFP_Release_Notebook_0_11_0.ipynb) | [![](https://www.tensorflow.org/images/GitHub-Mark-32px.png)View source on GitHub](https://github.com/tensorflow/probability/blob/main/tensorflow_probability/examples/jupyter_notebooks/TFP_Release_Notebook_0_11_0.ipynb) | [![](https://www.tensorflow.org/images/download_logo_32px.png)Download notebook](https://storage.googleapis.com/tensorflow_docs/probability/tensorflow_probability/examples/jupyter_notebooks/TFP_Release_Notebook_0_11_0.ipynb) |

### Installs \& imports

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    !pip3 install -U -q tensorflow==2.3.0 tensorflow_probability==0.11.0

    import tensorflow as tf
    import tensorflow_probability as tfp
    assert '0.11' in tfp.__version__, tfp.__version__
    assert '2.3' in tf.__version__, tf.__version__
    tfd = tfp.distributions
    tfb = tfp.bijectors
    tfpk = tfp.math.psd_kernels

    import matplotlib.pyplot as plt
    import numpy as np
    import scipy.interpolate
    import IPython
    import seaborn as sns

<br />

<br />

```
/usr/local/lib/python3.6/dist-packages/statsmodels/tools/_testing.py:19: FutureWarning: pandas.util.testing is deprecated. Use the functions in the public API at pandas.testing instead.
  import pandas.util.testing as tm
```

## TFP can run on JAX

*Note, this has moved up to `tfp.substrates` in nightly builds.*

    import jax
    from jax import config
    config.update('jax_enable_x64', True)

    def demo_jax():
      import tensorflow_probability.substrates.jax as tfp
      tfd = tfp.distributions
      tfb = tfp.bijectors

      @jax.jit
      def vmap_sample(seeds):
        d = tfb.Shift(2.)(tfb.Scale(2.)(tfd.Normal(0, 1)))
        return jax.vmap(lambda seed: d.sample(seed=seed))(seeds)

      def vmap_grad(seeds, sh, sc):
        d = lambda sh, sc: tfb.Shift(sh)(tfb.Scale(sc)(tfd.Normal(0, 1)))
        return jax.vmap(
            jax.grad(lambda sh, sc, samp: d(sh, sc).log_prob(samp), 
                     argnums=(0,1,2)),
            in_axes=(None, None, 0))(sh, sc, vmap_sample(seeds))

      seed = jax.random.PRNGKey(123)
      seeds = jax.random.split(seed, 10)
      print('jit vmap sample:', vmap_sample(seeds))
      print('vmap grad:', vmap_grad(seeds, 2., 2.))

      @jax.jit
      def hmm_sample(seed):
        init, transition, obsv, sample = jax.random.split(seed, num=4)
        d = tfd.HiddenMarkovModel(
            initial_distribution=tfd.Categorical(logits=jax.random.uniform(init, [3]) + .1),
            transition_distribution=tfd.Categorical(logits=jax.random.uniform(transition, [3, 3]) + .1),
            observation_distribution=tfd.Normal(loc=jax.random.normal(obsv, [3]), scale=1.),
            num_steps=10)
        samps = d.sample(seed=sample)
        return samps, d.log_prob(samps)
      print('hmm:', hmm_sample(jax.random.PRNGKey(123)))

      @jax.jit
      def nuts(seed):
        return tfp.mcmc.sample_chain(
            num_results=10,
            num_burnin_steps=50,
            current_state=np.zeros([75]),
            kernel=tfp.mcmc.NoUTurnSampler(
                target_log_prob_fn=lambda x: -(x - .2)**2 / .05,
                step_size=.1),
            trace_fn=None,
            seed=seed)
      print('nuts:')
      plt.hist(nuts(seed=jax.random.PRNGKey(7)).reshape(-1), bins=20, density=True)

    demo_jax()

```
/usr/local/lib/python3.6/dist-packages/jax/lib/xla_bridge.py:125: UserWarning: No GPU/TPU found, falling back to CPU.
  warnings.warn('No GPU/TPU found, falling back to CPU.')
jit vmap sample: [ 2.17746     2.6618252   3.427014   -0.80979496  5.87146     4.2002716
  1.2994273   1.2281269   3.5244293   4.1996603 ]
/usr/local/lib/python3.6/dist-packages/jax/numpy/lax_numpy.py:1531: FutureWarning: jax.numpy reductions won't accept lists and tuples in future versions, only scalars and ndarrays
  warnings.warn(msg, category=FutureWarning)
vmap grad: (DeviceArray([ 0.04436499,  0.1654563 ,  0.35675353, -0.70244873,
              0.96786499,  0.5500679 , -0.17514318, -0.19296828,
              0.38110733,  0.54991508], dtype=float64), DeviceArray([-0.4960635 , -0.44524843, -0.24545383,  0.48686844,
              1.37352526,  0.10514939, -0.43864973, -0.42552648,
             -0.20951441,  0.10481316], dtype=float64), DeviceArray([-0.04436499, -0.1654563 , -0.35675353,  0.7024487 ,
             -0.967865  , -0.5500679 ,  0.17514318,  0.19296828,
             -0.38110733, -0.5499151 ], dtype=float32))
hmm: (DeviceArray([-0.30260671, -0.38072154,  0.57980393, -0.30949971,
              1.22571819, -1.72733693, -1.13891736, -0.05021395,
              0.33300565, -0.31721795], dtype=float64), DeviceArray(-12.69673571, dtype=float64))
nuts:
```

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_kmF4AXAfHMDG_4.png)

## Inference with Sequential Monte Carlo (experimental)

    nmodes = 7
    loc_prior = tfd.MultivariateNormalDiag(loc=[0, 0], scale_diag=[2, 2])
    mode_locs = loc_prior.sample(nmodes, seed=(0, 1))
    logits_prior = tfd.Uniform()
    mode_logits = logits_prior.sample(nmodes, seed=(0, 2))

    make_mvn = lambda locs: tfd.MultivariateNormalDiag(
        loc=locs, scale_diag=tf.ones_like(locs))
    make_mixture = lambda locs, logits: tfd.MixtureSameFamily(
        mixture_distribution=tfd.Categorical(logits=logits),
        components_distribution=make_mvn(locs))

    true_dist = make_mixture(mode_locs, mode_logits)

    from mpl_toolkits import mplot3d
    x = np.linspace(-6, 6, 100)
    y = np.linspace(-6, 6, 100)

    X, Y = np.asarray(np.meshgrid(x, y), dtype=np.float32)

    Z = true_dist.prob(tf.stack([X, Y], axis=-1))
    fig = plt.figure(figsize=(10, 6))
    ax = plt.axes(projection='3d')
    ax.plot_surface(
        X, Y, Z, rstride=1, cstride=1, cmap='coolwarm', edgecolor='none')
    plt.title('source distribution')
    plt.show()

    data_size = 256
    samps = true_dist.sample(data_size, seed=(0, 3))
    sns.kdeplot(*samps.numpy().T)
    plt.scatter(*samps.numpy().T)
    plt.title('data')
    plt.show()

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_GEKG_KeWfy4s_0.png)

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_GEKG_KeWfy4s_1.png)

    nparticles = 2048
    seed = ()
    (n_stage, final_state, final_kernel_results
      ) = tfp.experimental.mcmc.sample_sequential_monte_carlo(
          prior_log_prob_fn=lambda locs, logits: (
              tf.reduce_sum(loc_prior.log_prob(locs)) +
              tf.reduce_sum(logits_prior.log_prob(logits))),
          likelihood_log_prob_fn=lambda locs, logits: (
              tfd.Sample(make_mixture(locs, logits), data_size).log_prob(samps)),
          current_state=(loc_prior.sample([nparticles, nmodes + 2]), 
                         logits_prior.sample([nparticles, nmodes + 2])),
    )

    # Identify any issues with particle weight collapse.
    plt.figure(figsize=(5,2))
    plt.plot(tf.sort(final_kernel_results.particle_info.tempered_log_prob));
    plt.title(f'Sampling done in {n_stage} stage');

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_DnA_u0ymf4CO_0.png)

    sampled_distributions = tfd.MixtureSameFamily(
        mixture_distribution=tfd.Categorical(
            logits=final_kernel_results.particle_info.tempered_log_prob),
        components_distribution=make_mixture(*final_state),
        name='ensembled_posterior')
    print(sampled_distributions)
    Z = sampled_distributions.prob(tf.stack([X, Y], axis=-1))
    fig = plt.figure(figsize=(10, 6))
    ax = plt.axes(projection='3d')
    ax.plot_surface(
        X, Y, Z, rstride=1, cstride=1, cmap='coolwarm', edgecolor='none')
    plt.title('Ensembled posterior probability density')
    plt.show()

    samps2 = sampled_distributions.sample(256, seed=(0, 4))
    sns.kdeplot(*samps2.numpy().T)
    # sns.kdeplot(*samps.numpy().T)
    plt.scatter(*samps2.numpy().T, alpha=.5, label='new samples')
    plt.scatter(*samps.numpy().T, alpha=.5, label='observed')
    plt.legend()
    plt.title('samples from ensembled posterior')
    plt.show()

```
tfp.distributions.MixtureSameFamily("ensembled_posterior", batch_shape=[], event_shape=[2], dtype=float32)
```

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_91oPKx4Hf6Mz_1.png)

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_91oPKx4Hf6Mz_2.png)

## Spherical distributions: SphericalUniform (new), PowerSpherical (new), VonMisesFisher

### `plot_spherical`

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    def plot_spherical(dist, nsamples):
      samples = dist.sample([nsamples], seed=123)
      probs = dist.prob(samples)
      samples = samples.numpy()
      probs = probs.numpy()
      # Show the dynamic range of the sample probabilities by re-scaling with min/max.
      minp, maxp = probs.min(), probs.max()
      ranged = np.float64(
          (probs - minp) / np.where(maxp - minp > 0, (maxp - minp), minp)) * .8 + .2

      data = list(map(list, samples))
      colors = map(plt.get_cmap('plasma'), ranged)
      colors = list(map(list, colors))

      js = """
        var scene = new THREE.Scene();
        var camera = new THREE.PerspectiveCamera( 75, 1.0, 0.1, 1000 );

        var renderer = new THREE.WebGLRenderer();
        renderer.setSize( 500, 500 );
        document.body.appendChild( renderer.domElement );

        var sphere_geom = new THREE.SphereBufferGeometry(1, 200, 200);
        var sphere_mat = new THREE.MeshBasicMaterial(
            {'opacity': 0.25, 'color': 0xFFFFFF, 'transparent': true});
        var sphere = new THREE.Mesh(sphere_geom, sphere_mat);
        sphere.position.set(0, 0, 0);
        scene.add(sphere);

        var points_data = %s;
        var points = [];
        for (var i = 0; i < points_data.length; i++) {
          points.push(new THREE.Vector3(
              points_data[i][0], points_data[i][1], points_data[i][2]));
        }

        var points_geom = new THREE.Geometry();
        points_geom.vertices = points;

        var colors_data = %s;
        var colors = [];
        for (var i = 0; i < colors_data.length; i++) {
          colors.push(new THREE.Color(
              colors_data[i][0], colors_data[i][1], colors_data[i][2]));
        }
        points_geom.colors = colors;
        var points_mat = new THREE.PointsMaterial({'size': 0.015});
        points_mat.vertexColors = THREE.VertexColors;
        var points = new THREE.Points(points_geom, points_mat);
        scene.add(points);

        camera.position.x = 0;
        camera.position.y = -2;
        camera.position.z = 2;
        camera.lookAt(new THREE.Vector3(0, 0, 0));

        controls = new THREE.TrackballControls(camera, renderer.domElement);
        controls.rotateSpeed = 1.0;
        controls.zoomSpeed = 1.2;
        controls.panSpeed = 0.8;
        controls.noZoom = false;
        controls.noPan = false;
        controls.staticMoving = false;
        controls.dynamicDampingFactor = 0.15;

        /* 
        Keep the camera pointing the same direction it was before.  However, 
        this does not generally have the same actual target as the original camera
        lookAt, only the same direction.  So when the user rotates the view it 
        might not have the expected origin of rotation. 
        */
        look_at = new THREE.Vector3(0, 0, -1);
        look_at.applyQuaternion(camera.quaternion).add(camera.position)
        controls.target = look_at;

        var LookAt = function(x, y, z) {
          camera.lookAt(new THREE.Vector3(x, y, z));
          controls.target.set(x, y, z);
        };
        LookAt(0, 0, 0);

        var animate = function () {
          requestAnimationFrame( animate );
          controls.update();
          renderer.render( scene, camera );
        };

        animate();
      """ % (repr(data), repr(colors))

      IPython.display.display_html("""
      <script type='text/javascript' src='https://ajax.googleapis.com/ajax/libs/threejs/r84/three.min.js'></script>
      <script type='text/javascript' src='https://cdn.rawgit.com/mrdoob/three.js/a1daef37/examples/js/controls/TrackballControls.js'></script>
      <script type='text/javascript'>
      %s
      </script>
      <b>Spin me!</b>
      """ % js, raw=True)

<br />

<br />

### Visualizing `tfd.SphericalUniform` in 3 dimensions

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    nsamples = 2000 
    d = tfd.SphericalUniform(dimension=3)
    plot_spherical(d, nsamples)

<br />

<br />

<iframe src="https:///frame/probability/examples/TFP_Release_Notebook_0_11_0_aa240a061606c70e0c2ac531d3bc4a2f23d3eb6fcc35ecbf9185cfc639743753.frame" class="framebox inherit-locale " allow="clipboard-write https://" allowfullscreen is-upgraded></iframe>

### Visualizing `tfd.PowerSpherical` in 3 dimensions

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    concentration = 5.0 
    nsamples = 2000 
    d = tfd.PowerSpherical(
        mean_direction=tf.nn.l2_normalize(np.float64([1, 1, 1]), axis=-1), 
        concentration=np.float64(concentration))
    plot_spherical(d, nsamples)

<br />

<br />

<iframe src="https:///frame/probability/examples/TFP_Release_Notebook_0_11_0_3f80359bd6186ae2142c0b23cb7fea020340a1f6bfd1568a74d888a68868d0a0.frame" class="framebox inherit-locale " allow="clipboard-write https://" allowfullscreen is-upgraded></iframe>

### Visualizing `tfd.VonMisesFisher` in 3 dimensions

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    concentration = 5.0 
    nsamples = 2000 
    vmf = tfp.distributions.VonMisesFisher(
        mean_direction=tf.nn.l2_normalize(np.float64([1, 1, 1]), axis=-1), 
        concentration=np.float64(concentration))
    plot_spherical(vmf, nsamples)

<br />

<br />

<iframe src="https:///frame/probability/examples/TFP_Release_Notebook_0_11_0_46423c7349a46f4f66a15ba8b35322a198e14a262b727cd7a1b61da018d97133.frame" class="framebox inherit-locale " allow="clipboard-write https://" allowfullscreen is-upgraded></iframe>

## New Bijectors

### `tfb.Sinh`

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    plt.figure(figsize=(12, 4))
    plt.subplot(121)
    xs = np.linspace(-7, 7, 100)
    plt.plot(xs, tfb.Sinh()(xs), label='sinh(x)')
    plt.plot(xs, tf.math.exp(tfb.Sinh().forward_log_det_jacobian(xs, event_ndims=0)), ':', label='sinh derivative');
    plt.legend()
    plt.title('Sinh bijector')
    plt.subplot(122)
    xs *= 20
    plt.plot(xs, tfb.Sinh()(tfd.Uniform(-7, 7)).cdf(xs))
    plt.title('CDF of Sinh-transformed Uniform(-7,7)');

<br />

<br />

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_uLDfGwOmFATa_0.png)

### `tfb.GompertzCDF`

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    plt.figure(figsize=(12, 4))
    plt.subplot(121)
    xs = np.linspace(0, 7, 100).astype(np.float32)
    b = tfb.GompertzCDF(.5, .5)
    plt.plot(xs, b(xs), label='GompertzCDF(.5, .5)(x)')
    plt.plot(xs, tf.math.exp(b.forward_log_det_jacobian(xs, event_ndims=0)), ':', label='GompertzCDF derivative');
    plt.legend()
    plt.title('GompertzCDF bijector')
    plt.subplot(122)
    d = tfb.Invert(b)(tfd.Uniform(0, 1))
    plt.plot(xs, d.cdf(xs), label='cdf(x)')
    plt.plot(xs, d.prob(xs), label='p(x)')
    plt.legend()
    plt.title('pdf/cdf of Gompertz(.5, .5) dist');

<br />

<br />

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_X_09anOqUqsE_0.png)

## New distributions

### `tfd.TruncatedCauchy`

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    d = tfd.TruncatedCauchy(1, 1, .3, 2.1)
    samples = tf.sort(d.sample(2000, seed=(0, 1)))
    plt.hist(samples, bins=100, density=True, label='samples')
    plt.plot(samples, d.prob(samples), label='p(x)')
    plt.title('tfd.TruncatedCauchy')
    plt.legend();

<br />

<br />

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_xU2caROk3TMA_0.png)

### `tfd.Bates` (mean of `n` uniform samples)

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    plt.figure(figsize=(10, 5))
    for i, n in enumerate((1, 3, 7, 13)):
      plt.subplot(221+i)
      d = tfd.Bates(total_count=n)
      samples = tf.sort(d.sample(2000, seed=(1, 2)))
      plt.hist(samples, bins=100, density=True, label='samples')
      plt.plot(samples, d.prob(samples), label='p(x)')
      plt.title(f'tfd.Bates | n={n}')
      plt.legend()
      plt.tight_layout()

<br />

<br />

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_H0o-nCEi38vm_0.png)

### `tfd.LogLogistic`

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    d = tfd.LogLogistic(0, .1)
    samples = tf.sort(d.sample(2000, seed=(2, 3)))
    plt.hist(samples, bins=100, density=True, log=True, label='samples')
    plt.plot(samples, d.prob(samples), label='p(x)')
    plt.legend()
    plt.title('tfd.LogLogistic(0, .1)');

<br />

<br />

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_ChFLxqrK42kT_0.png)

### `tfd.JohnsonSU`

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    stats = ('loc', 'scale', 'tailweight', 'skewness')
    plt.figure(figsize=(12, 4))
    for i, d in enumerate([
        tfd.JohnsonSU(skewness=3, tailweight=2, loc=0, scale=1),
        tfd.JohnsonSU(skewness=-3, tailweight=2, loc=0, scale=1)]):
      plt.subplot(121+i)
      samples = tf.sort(d.sample(2000, seed=(2, 4)))
      plt.hist(samples, bins=100, density=True, label='samples')
      plt.plot(samples, d.prob(samples), label='p(x)')
      plt.legend()
      plt.title(f'tfd.JohnsonSU { {k: v for (k, v) in d.parameters.items() if k in stats} }')
      plt.tight_layout();
<br />

<br />

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_OdElYf8V5rsG_0.png)

### `tfd.ContinuousBernoulli`

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    d = tfd.ContinuousBernoulli(logits=tfb.Sigmoid().inverse(.1))
    samples = tf.sort(d.sample(2000, seed=(2, 3)))
    plt.hist(samples, bins=100, density=True, label='samples')
    plt.plot(samples, d.prob(samples), label='p(x)')
    plt.legend()
    plt.title('tfd.ContinuousBernoulli(logits=tfb.Sigmoid().inverse(.1))');

<br />

<br />

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_cjXyCRXQ7WT6_0.png)

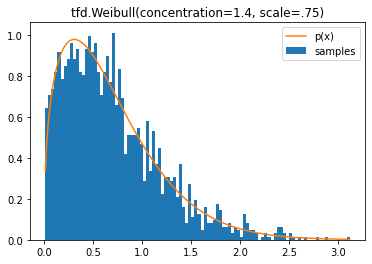
### `tfd.Weibull`

<br />

<button type="button" class="button-red button expand-control">Toggle code</button>

<br />

    d = tfd.Weibull(concentration=1.4, scale=.75)
    samples = tf.sort(d.sample(2000, seed=(2, 3)))
    plt.hist(samples, bins=100, density=True, label='samples')
    plt.plot(samples, d.prob(samples), label='p(x)')
    plt.legend()
    plt.title('tfd.Weibull(concentration=1.4, scale=.75)');

<br />

<br />

![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_Tx3XuyRk8Oaa_0.png)

## Auto-vectorized sampling with `JointDistribution*AutoBatched`

If you've ever struggled getting batch dimensions to line up correctly in your joint distributions, this is for you.

### Ever written code like this?

    data = tf.random.stateless_normal([7], seed=(1,2))

    @tfd.JointDistributionCoroutine
    def model():
      root = tfd.JointDistributionCoroutine.Root
      scale = yield root(tfd.Gamma(1, 1, name='scale'))
      yield tfd.Normal(tf.zeros_like(data), scale)

    model.sample()

```
(<tf.Tensor: shape=(), dtype=float32, numpy=4.1253977>,
 <tf.Tensor: shape=(7,), dtype=float32, numpy=
 array([-2.814606  ,  0.81064916, -1.1025742 , -1.8684998 , -2.9547117 ,
        -0.19623983, -0.15587877], dtype=float32)>)
```

### Then hit exceptions drawing non-scalar samples?

    print(model.sample(1), '\n  (^^ silent badness: the second value lacks a leading (1,) shape)')
    print('sampling (3,) will break:')
    import traceback
    try:
      model.sample(3)
    except ValueError as e:
      traceback.print_exc()

```
(<tf.Tensor: shape=(1,), dtype=float32, numpy=array([0.15810375], dtype=float32)>, <tf.Tensor: shape=(7,), dtype=float32, numpy=
array([-0.03214252,  0.15187298, -0.08423525, -0.03807954,  0.25466064,
       -0.14433853,  0.2543037 ], dtype=float32)>) 
  (^^ silent badness: the second value lacks a leading (1,) shape)
sampling (3,) will break:
Traceback (most recent call last):
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/normal.py", line 243, in _parameter_control_dependencies
    self._batch_shape()
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/normal.py", line 176, in _batch_shape
    return tf.broadcast_static_shape(self.loc.shape, self.scale.shape)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow/python/util/dispatch.py", line 201, in wrapper
    return target(*args, **kwargs)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow/python/ops/array_ops.py", line 554, in broadcast_static_shape
    return common_shapes.broadcast_shape(shape_x, shape_y)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow/python/framework/common_shapes.py", line 107, in broadcast_shape
    % (shape_x, shape_y))
ValueError: Incompatible shapes for broadcasting: (7,) and (3,)

During handling of the above exception, another exception occurred:

Traceback (most recent call last):
  File "<ipython-input-28-ab2fdd83415c>", line 4, in <module>
    model.sample(3)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/distribution.py", line 939, in sample
    return self._call_sample_n(sample_shape, seed, name, **kwargs)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/joint_distribution.py", line 532, in _call_sample_n
    **kwargs)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/internal/distribution_util.py", line 1324, in _fn
    return fn(*args, **kwargs)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/joint_distribution.py", line 414, in _sample_n
    **kwargs)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/joint_distribution.py", line 451, in _call_flat_sample_distributions
    ds, xs = self._flat_sample_distributions(sample_shape, seed, value)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/joint_distribution_coroutine.py", line 278, in _flat_sample_distributions
    d = gen.send(next_value)
  File "<ipython-input-19-d59a243cd9c8>", line 7, in model
    yield tfd.Normal(tf.zeros_like(data), scale)
  File "<decorator-gen-306>", line 2, in __init__
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/distribution.py", line 334, in wrapped_init
    default_init(self_, *args, **kwargs)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/normal.py", line 148, in __init__
    name=name)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/distribution.py", line 552, in __init__
    d for d in self._parameter_control_dependencies(is_init=True)
  File "/usr/local/lib/python3.6/dist-packages/tensorflow_probability/python/distributions/normal.py", line 248, in _parameter_control_dependencies
    self.loc.shape, self.scale.shape))
ValueError: Arguments `loc` and `scale` must have compatible shapes; loc.shape=(7,), scale.shape=(3,).
```

### Now, you can use `tfd.JointDistributionCoroutineAutoBatched` \& friends

You write a "scalar" sampling routine, then draw arbitrary sample shapes.

    @tfd.JointDistributionCoroutineAutoBatched
    def model_auto():
      scale = yield tfd.Gamma(1, 1, name='scale')
      yield tfd.Normal(tf.zeros_like(data), scale)

    print(model_auto.sample(), '\n  (scalar sample)')
    print(model_auto.sample(1), '\n  ((1,) sample)')
    print(model_auto.sample(3), '\n  ((3,) sample)')

```
(<tf.Tensor: shape=(), dtype=float32, numpy=1.5234255>, <tf.Tensor: shape=(7,), dtype=float32, numpy=
array([-0.7177643 , -2.7825186 , -1.1250918 ,  0.57446253, -1.0755515 ,
        2.6673915 , -1.776087  ], dtype=float32)>) 
  (scalar sample)
WARNING:tensorflow:Note that RandomUniformInt inside pfor op may not give same output as inside a sequential loop.
WARNING:tensorflow:Note that RandomStandardNormal inside pfor op may not give same output as inside a sequential loop.
(<tf.Tensor: shape=(1,), dtype=float32, numpy=array([0.48698178], dtype=float32)>, <tf.Tensor: shape=(1, 7), dtype=float32, numpy=
array([[ 0.44244727, -0.548889  ,  0.29392514, -0.5249126 , -0.6618264 ,
         0.06925056, -0.32040703]], dtype=float32)>) 
  ((1,) sample)
WARNING:tensorflow:Note that RandomUniformInt inside pfor op may not give same output as inside a sequential loop.
WARNING:tensorflow:Note that RandomStandardNormal inside pfor op may not give same output as inside a sequential loop.
(<tf.Tensor: shape=(3,), dtype=float32, numpy=array([0.5501703, 1.9277483, 2.7804365], dtype=float32)>, <tf.Tensor: shape=(3, 7), dtype=float32, numpy=
array([[-1.1568309 ,  0.02062727,  0.04918252, -0.08978909,  0.6446161 ,
        -0.16725235, -0.27897784],
       [-2.9246418 , -1.2733852 ,  1.0071639 , -0.4655921 , -4.1095695 ,
         0.1298227 ,  3.0307395 ],
       [-2.7411313 ,  1.6211014 , -1.600051  , -1.4009917 ,  4.081262  ,
         1.7097493 ,  2.8525631 ]], dtype=float32)>) 
  ((3,) sample)
```

## Reproducible sampling, even in eager

    tf.random.set_seed(123)
    print('Stateful sampling:\t\t', 
          tfd.Normal(0, 1).sample(seed=234),
          'then', 
          tfd.Normal(0, 1).sample(seed=234))  

    # Why are they different?
    # TF samplers are stateful by default (TF maintains is a global PRNG).
    # How to get reproducible results in eager mode?
    tf.random.set_seed(123)
    print('Stateful sampling (set_seed):\t',
          tfd.Normal(0, 1).sample(seed=234))

    # And what about tf.function?
    @tf.function
    def sample_normal():
      return tfd.Normal(0, 1).sample(seed=234)
    tf.random.set_seed(123)
    print('tf.function:\t\t', sample_normal(), 'vs', sample_normal())
    tf.random.set_seed(123)
    print('tf.function (set_seed):\t', sample_normal())

    # Using a Tensor seed (or a tuple, which TFP will convert to a tensor) induces
    # TFP behavior analagous to the tf.random.stateless_* ops. This sampling 
    # is fully deterministic.
    print('Stateless sampling (tuple):\t\t',
          tfd.Normal(0, 1).sample(seed=(1, 23)))
    print('Stateless sampling (tensor):\t\t',
          tfd.Normal(0, 1).sample(seed=tf.constant([1, 23], dtype=tf.int32)))
    # Even in tf.function
    @tf.function
    def sample_normal():
      return tfd.Normal(0, 1).sample(seed=(1, 23))
    print('Stateless sampling (tf.function):\t', sample_normal())

    # And independent of global seeds.
    tf.random.set_seed(321)
    print('Stateless sampling (ignores set_seed):\t', sample_normal())

```
Stateful sampling:         tf.Tensor(0.54054874, shape=(), dtype=float32) then tf.Tensor(-1.5518123, shape=(), dtype=float32)
Stateful sampling (set_seed):  tf.Tensor(0.54054874, shape=(), dtype=float32)
tf.function:       tf.Tensor(0.54054874, shape=(), dtype=float32) vs tf.Tensor(-1.5518123, shape=(), dtype=float32)
tf.function (set_seed):    tf.Tensor(0.54054874, shape=(), dtype=float32)
Stateless sampling (tuple):        tf.Tensor(-0.36107817, shape=(), dtype=float32)
Stateless sampling (tensor):       tf.Tensor(-0.36107817, shape=(), dtype=float32)
Stateless sampling (tf.function):  tf.Tensor(-0.36107817, shape=(), dtype=float32)
Stateless sampling (ignores set_seed):     tf.Tensor(-0.36107817, shape=(), dtype=float32)
```

### Similarly, [`tfp.mcmc.sample_chain`](https://www.tensorflow.org/probability/api_docs/python/tfp/mcmc/sample_chain) now accepts stateless seeds

This is passed to underlying kernels, which must be updated to accept a `seed` argument to `one_step` if they make random proposals. (Built-in kernels are already updated.)

    kernel = tfp.mcmc.HamiltonianMonteCarlo(lambda x: -(x - .2)**2,
                                            step_size=1.,
                                            num_leapfrog_steps=2)
    print_n_lines = lambda x, n: print('\n'.join(repr(x).split('\n')[:n] + ['...']))
    print_n_lines(
        tfp.mcmc.sample_chain(
            num_results=5,
            num_burnin_steps=100,
            current_state=tf.zeros([3]),
            kernel=kernel,
            trace_fn=lambda state, kr: kr,
            seed=(1, 2)),
        17)
    print('And again (reproducibly)...')
    print_n_lines(
        tfp.mcmc.sample_chain(
            num_results=5,
            num_burnin_steps=100,
            current_state=tf.zeros([3]),
            kernel=kernel,
            trace_fn=lambda state, kr: kr,
            seed=(1, 2)),
        17)

```
StatesAndTrace(
  all_states=<tf.Tensor: shape=(5, 3), dtype=float32, numpy=
    array([[ 4.0000078e-01,  3.9999962e-01,  3.9999855e-01],
           [-8.3446503e-07,  3.5762787e-07,  1.5497208e-06],
           [ 4.0000081e-01,  3.9999965e-01,  3.9999846e-01],
           [-8.3446503e-07,  4.7683716e-07,  1.5497208e-06],
           [ 4.0000087e-01,  3.9999962e-01,  3.9999843e-01]], dtype=float32)>,
  trace=MetropolisHastingsKernelResults(
      accepted_results=UncalibratedHamiltonianMonteCarloKernelResults(
          log_acceptance_correction=<tf.Tensor: shape=(5, 3), dtype=float32, numpy=
            array([[ 0.0000000e+00, -2.9802322e-08,  0.0000000e+00],
                   [ 5.9604645e-08,  1.1175871e-08,  1.1920929e-07],
                   [-2.9802322e-08, -2.7939677e-09,  2.7939677e-09],
                   [ 0.0000000e+00,  0.0000000e+00, -5.9604645e-08],
                   [ 1.4901161e-08, -1.7881393e-07,  0.0000000e+00]], dtype=float32)>,
          target_log_prob=<tf.Tensor: shape=(5, 3), dtype=float32, numpy=
            array([[-0.04000031, -0.03999985, -0.03999942],
...
And again (reproducibly)...
StatesAndTrace(
  all_states=<tf.Tensor: shape=(5, 3), dtype=float32, numpy=
    array([[ 4.0000078e-01,  3.9999962e-01,  3.9999855e-01],
           [-8.3446503e-07,  3.5762787e-07,  1.5497208e-06],
           [ 4.0000081e-01,  3.9999965e-01,  3.9999846e-01],
           [-8.3446503e-07,  4.7683716e-07,  1.5497208e-06],
           [ 4.0000087e-01,  3.9999962e-01,  3.9999843e-01]], dtype=float32)>,
  trace=MetropolisHastingsKernelResults(
      accepted_results=UncalibratedHamiltonianMonteCarloKernelResults(
          log_acceptance_correction=<tf.Tensor: shape=(5, 3), dtype=float32, numpy=
            array([[ 0.0000000e+00, -2.9802322e-08,  0.0000000e+00],
                   [ 5.9604645e-08,  1.1175871e-08,  1.1920929e-07],
                   [-2.9802322e-08, -2.7939677e-09,  2.7939677e-09],
                   [ 0.0000000e+00,  0.0000000e+00, -5.9604645e-08],
                   [ 1.4901161e-08, -1.7881393e-07,  0.0000000e+00]], dtype=float32)>,
          target_log_prob=<tf.Tensor: shape=(5, 3), dtype=float32, numpy=
            array([[-0.04000031, -0.03999985, -0.03999942],
...
```

## Pretty printing MCMC kernel results

    tfp.mcmc.RandomWalkMetropolis(tfd.Uniform(0, 10).log_prob).bootstrap_results(1.)

```
MetropolisHastingsKernelResults(
  accepted_results=UncalibratedRandomWalkResults(
      log_acceptance_correction=<tf.Tensor: shape=(), dtype=float32, numpy=0.0>,
      target_log_prob=<tf.Tensor: shape=(), dtype=float32, numpy=-2.3025851>,
      seed=[]
    ),
  is_accepted=<tf.Tensor: shape=(), dtype=bool, numpy=True>,
  log_accept_ratio=<tf.Tensor: shape=(), dtype=float32, numpy=0.0>,
  proposed_state=1.0,
  proposed_results=UncalibratedRandomWalkResults(
      log_acceptance_correction=<tf.Tensor: shape=(), dtype=float32, numpy=0.0>,
      target_log_prob=<tf.Tensor: shape=(), dtype=float32, numpy=-2.3025851>,
      seed=<tf.Tensor: shape=(2,), dtype=int32, numpy=array([0, 0], dtype=int32)>
    ),
  extra=[],
  seed=<tf.Tensor: shape=(2,), dtype=int32, numpy=array([0, 0], dtype=int32)>
)
```

## CompositeTensor (experimental)

Save on tracing a [`tf.function`](https://www.tensorflow.org/api_docs/python/tf/function). Return distributions from a [`tf.function`](https://www.tensorflow.org/api_docs/python/tf/function).

    @tf.function
    def get_mean(d):
      return d.mean()

    print(get_mean(tfp.experimental.as_composite(tfd.BetaBinomial(100., 2., 7.))))

    @tf.function
    def returns_dist(logits):
      return tfp.experimental.as_composite(tfd.Binomial(10., logits=logits))

    print(returns_dist(tf.constant(0.)),
          returns_dist(tf.constant(0.)).sample(seed=(2, 3)))

```
tf.Tensor(22.222221, shape=(), dtype=float32)
tfp.distributions.BinomialCT("Binomial", batch_shape=[], event_shape=[], dtype=float32) tf.Tensor(5.0, shape=(), dtype=float32)
```

## Did you know: Batch slicing distributions

    def demo_batch_slice():
      d = tfd.Normal(
          loc=tf.random.stateless_normal([100, 20, 3], seed=(1,2)),
          scale=1.)
      print(d, '\n  (original dist)')
      print(d[0], '\n  (0th element of the first batch dimension)')
      print(d[::2, ..., 1], '\n  (every other element of first dim  x  middle element of final dim)\n')

      d = tfd.Dirichlet(
          concentration=tf.random.stateless_uniform([100, 20, 3, 7], seed=(1,2)))
      print(d, '\n  (original dist)')
      print(d[:, 0], '\n  (0th element of the second dimension)')
      print(d[::2, ..., 1], '\n  (every other element of first dim  x  middle element of final dim)')
    demo_batch_slice()

```
tfp.distributions.Normal("Normal", batch_shape=[100, 20, 3], event_shape=[], dtype=float32) 
  (original dist)
tfp.distributions.Normal("Normal", batch_shape=[20, 3], event_shape=[], dtype=float32) 
  (0th element of the first batch dimension)
tfp.distributions.Normal("Normal", batch_shape=[50, 20], event_shape=[], dtype=float32) 
  (every other element of first dim  x  middle element of final dim)

tfp.distributions.Dirichlet("Dirichlet", batch_shape=[100, 20, 3], event_shape=[7], dtype=float32) 
  (original dist)
tfp.distributions.Dirichlet("Dirichlet", batch_shape=[100, 3], event_shape=[7], dtype=float32) 
  (0th element of the second dimension)
tfp.distributions.Dirichlet("Dirichlet", batch_shape=[50, 20], event_shape=[7], dtype=float32) 
  (every other element of first dim  x  middle element of final dim)
```

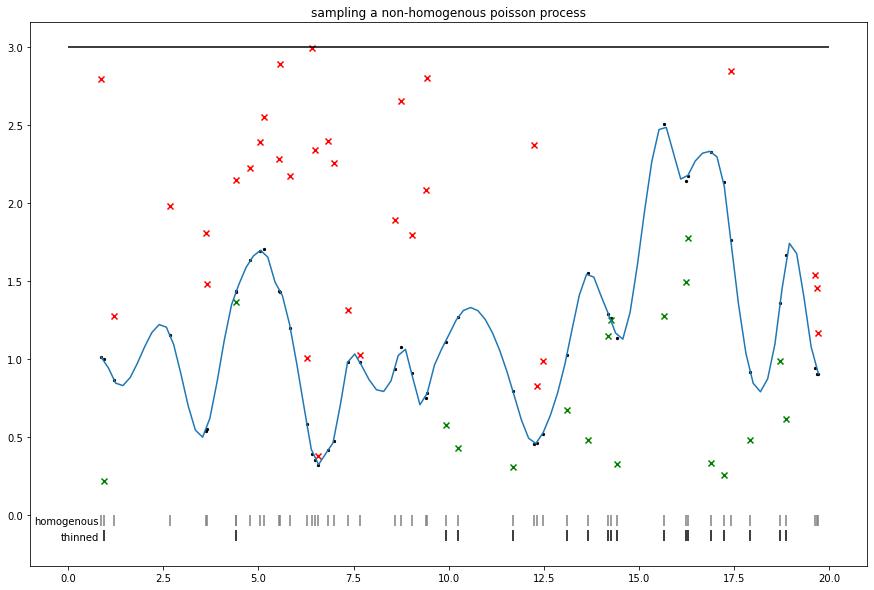
## Random novelties: Sampling a sigmoidal Cox (nonhomogenous Poisson) process

We can use the thinning procedure proposed in [Adams et al.](https://icml.cc/Conferences/2009/papers/255.pdf)

Note that a similar thinning approach is relevant to some approaches to nonreversible MCMC (e.g. zig-zag and bouncy particle samplers), where an upper bound on intensity can be used to sample nonhomogenous events.

    def sigmoidal_cox_process():
      V = 20.
      lam0 = 3.
      n_homog = tfd.Poisson(V * lam0).sample(seed=(0, 1))
      homog_locs = tf.sort(tfd.Uniform(0., V).sample(n_homog, seed=(0, 2)))
      homog_intensities = tfd.GaussianProcess(
          tfpk.MaternThreeHalves(), 
          index_points=homog_locs[:, tf.newaxis]).sample(seed=(0, 3))

      plt.figure(figsize=(15,10))
      plt.title('sampling a non-homogenous poisson process')
      plt.hlines(lam0, xmin=0., xmax=V)

      sigm_int = tf.math.sigmoid(homog_intensities) * lam0

      sp = scipy.interpolate.make_interp_spline(homog_locs, sigm_int)
      xs = np.linspace(homog_locs[0], homog_locs[-1], 100)
      ys = scipy.interpolate.splev(xs, sp)
      plt.plot(xs, ys)

      plt.scatter(homog_locs, sigm_int, s=5., c='black')

      unif = tfd.Uniform(0, lam0).sample(n_homog)
      plt.scatter(homog_locs, tf.where(unif < sigm_int, np.nan, unif), c='r', marker='x')
      plt.scatter(homog_locs, tf.where(unif > sigm_int, np.nan, unif), c='g', marker='x')

      plt.vlines(homog_locs, 0, -.07, colors='gray', )
      plt.text(.8, -.06, 'homogenous', dict(fontsize='medium'), horizontalalignment='right')

      nonhomog_locs = tf.gather(homog_locs, tf.where(unif < sigm_int))
      plt.vlines(nonhomog_locs, -.1, -.17, colors='black')
      plt.text(.8, -.16, 'thinned', dict(fontsize='medium'), horizontalalignment='right')
      plt.show()

    sigmoidal_cox_process()
![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_joNOzm68_ZzO_0.png)

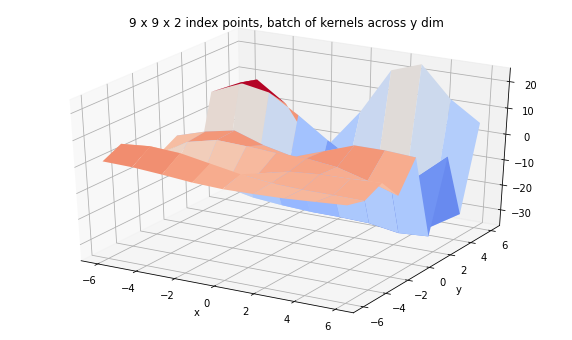
## Did you know: Batches of GPs

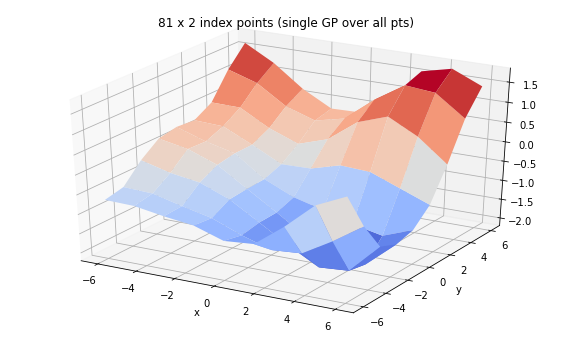
Gaussian Processes are distributions over functions. Here, we will parameterize by a kernel and a set of index points and showcase some of the batching behavior.

(TFP also supports a GP regression model, where the observations at observed index points determine the posterior distribution over functions on a set of index points, see [`tfd.GaussianProcessRegressionModel`](https://www.tensorflow.org/probability/api_docs/python/tfp/distributions/GaussianProcessRegressionModel).)

    from mpl_toolkits import mplot3d
    x = np.linspace(-6, 6, 9)
    y = np.linspace(-6, 6, 9)

    X, Y = np.asarray(np.meshgrid(x, y), dtype=np.float32)

    print('We can set up a single GP over many examples of 2d feature')
    gp = tfd.GaussianProcess(
        tfpk.ExponentiatedQuadratic(length_scale=3., feature_ndims=1),
        index_points=tf.reshape(tf.stack([X, Y], axis=-1), (-1, 2)),
        jitter=1e-3)
    print(gp)
    Z = tf.reshape(gp.sample(seed=(0,3)), X.shape)
    fig = plt.figure(figsize=(10, 6))
    ax = plt.axes(projection='3d')
    ax.plot_surface(
        X, Y, Z, rstride=1, cstride=1, cmap='coolwarm', edgecolor='none');
    ax.set_xlabel('x');ax.set_ylabel('y');
    ax.set_title('81 x 2 index points (single GP over all pts)')
    plt.show()

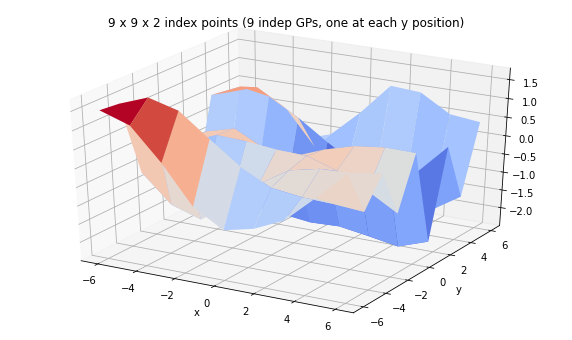
    print('We can have a batch of independent GPs with their own sets of index points.')
    batch_gp = tfd.GaussianProcess(
        tfpk.ExponentiatedQuadratic(length_scale=3., feature_ndims=1),
        index_points=tf.stack([X, Y], axis=-1),
        jitter=1e-3)
    print(batch_gp)
    Z_batch = batch_gp.sample(seed=(5,7))
    fig = plt.figure(figsize=(10, 6))
    ax = plt.axes(projection='3d')
    ax.plot_surface(
        X, Y, Z_batch, rstride=1, cstride=1, cmap='coolwarm', edgecolor='none');
    ax.set_xlabel('x');ax.set_ylabel('y');
    ax.set_title('9 x 9 x 2 index points (9 indep GPs, one at each y position)');
    plt.show()

    print('We can also have a corresponding batch of kernels.')
    kernel = tfpk.ExponentiatedQuadratic(length_scale=3.,
                                         amplitude=tf.linspace(1., 20., 9),
                                         feature_ndims=1)
    print(kernel)
    batch_gp_kernel = tfd.GaussianProcess(
        kernel,
        index_points=tf.stack([X, Y], axis=-1),
        jitter=1e-3)
    print(batch_gp_kernel)
    Z_batch_kernel = batch_gp_kernel.sample(seed=(5,7))

    fig = plt.figure(figsize=(10, 6))
    ax = plt.axes(projection='3d')
    ax.plot_surface(
        X, Y, Z_batch_kernel, rstride=1, cstride=1, cmap='coolwarm', edgecolor='none');
    ax.set_xlabel('x');ax.set_ylabel('y');
    ax.set_title('9 x 9 x 2 index points, batch of kernels across y dim');

```
We can set up a single GP over many examples of 2d feature
tfp.distributions.GaussianProcess("GaussianProcess", batch_shape=[], event_shape=[81], dtype=float32)
```
![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_4A-fthDGmF6E_1.png)

```
We can have a batch of independent GPs with their own sets of index points.
tfp.distributions.GaussianProcess("GaussianProcess", batch_shape=[9], event_shape=[9], dtype=float32)
```
![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_4A-fthDGmF6E_3.png)

```
We can also have a corresponding batch of kernels.
tfp.math.psd_kernels.ExponentiatedQuadratic("ExponentiatedQuadratic", batch_shape=(9,), feature_ndims=1, dtype=float32)
tfp.distributions.GaussianProcess("GaussianProcess", batch_shape=[9], event_shape=[9], dtype=float32)
```
![png](https://www.tensorflow.org/static/probability/examples/TFP_Release_Notebook_0_11_0_files/output_4A-fthDGmF6E_5.png)