# tf.tensor_scatter_nd_update
|---|
| [ View source on GitHub](https://github.com/tensorflow/tensorflow/blob/v2.13.1/tensorflow/python/ops/array_ops.py#L5647-L5931) |
Scatter `updates` into an existing tensor according to `indices`.
#### View aliases
**Compat aliases for migration**
See
[Migration guide](https://www.tensorflow.org/guide/migrate) for
more details.
[`tf.compat.v1.tensor_scatter_nd_update`](https://www.tensorflow.org/api_docs/python/tf/tensor_scatter_nd_update), [`tf.compat.v1.tensor_scatter_update`](https://www.tensorflow.org/api_docs/python/tf/tensor_scatter_nd_update)
tf.tensor_scatter_nd_update(
tensor, indices, updates, name=None
)
This operation creates a new tensor by applying sparse `updates` to the
input `tensor`. This is similar to an index assignment.
# Not implemented: tensors cannot be updated inplace.
tensor[indices] = updates
If an out of bound index is found on CPU, an error is returned.
>
> > [!WARNING]
> > **Warning:** There are some GPU specific semantics for this operation.
>
> - If an out of bound index is found, the index is ignored.
> - The order in which updates are applied is nondeterministic, so the output will be nondeterministic if `indices` contains duplicates.
This operation is very similar to [`tf.scatter_nd`](https://www.tensorflow.org/versions/r2.13/api_docs/python/tf/scatter_nd), except that the updates are
scattered onto an existing tensor (as opposed to a zero-tensor). If the memory
for the existing tensor cannot be re-used, a copy is made and updated.
#### In general:
- `indices` is an integer tensor - the indices to update in `tensor`.
- `indices` has **at least two** axes, the last axis is the depth of the index vectors.
- For each index vector in `indices` there is a corresponding entry in `updates`.
- If the length of the index vectors matches the rank of the `tensor`, then the index vectors each point to scalars in `tensor` and each update is a scalar.
- If the length of the index vectors is less than the rank of `tensor`, then the index vectors each point to the slices of `tensor` and shape of the updates must match that slice.
Overall this leads to the following shape constraints:
assert tf.rank(indices) >= 2
index_depth = indices.shape[-1]
batch_shape = indices.shape[:-1]
assert index_depth <= tf.rank(tensor)
outer_shape = tensor.shape[:index_depth]
inner_shape = tensor.shape[index_depth:]
assert updates.shape == batch_shape + inner_shape
Typical usage is often much simpler than this general form, and it
can be better understood starting with simple examples:
### Scalar updates
The simplest usage inserts scalar elements into a tensor by index.
In this case, the `index_depth` must equal the rank of the
input `tensor`, slice each column of `indices` is an index into an axis of the
input `tensor`.
In this simplest case the shape constraints are:
num_updates, index_depth = indices.shape.as_list()
assert updates.shape == [num_updates]
assert index_depth == tf.rank(tensor)`
For example, to insert 4 scattered elements in a rank-1 tensor with
8 elements.
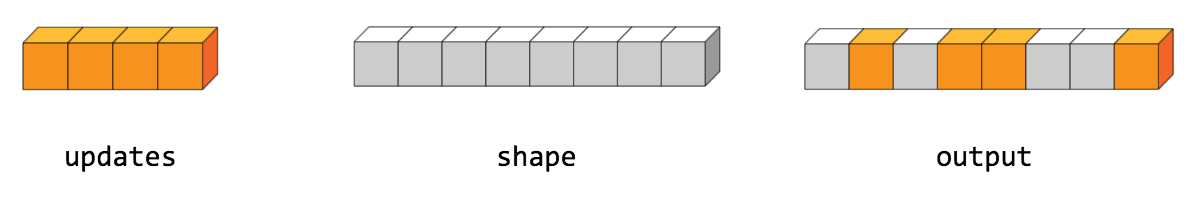
This scatter operation would look like this:
tensor = [0, 0, 0, 0, 0, 0, 0, 0] # tf.rank(tensor) == 1
indices = [[1], [3], [4], [7]] # num_updates == 4, index_depth == 1
updates = [9, 10, 11, 12] # num_updates == 4
print(tf.tensor_scatter_nd_update(tensor, indices, updates))
tf.Tensor([ 0 9 0 10 11 0 0 12], shape=(8,), dtype=int32)
The length (first axis) of `updates` must equal the length of the `indices`:
`num_updates`. This is the number of updates being inserted. Each scalar
update is inserted into `tensor` at the indexed location.
For a higher rank input `tensor` scalar updates can be inserted by using an
`index_depth` that matches [`tf.rank(tensor)`](https://www.tensorflow.org/versions/r2.13/api_docs/python/tf/rank):
tensor = [[1, 1], [1, 1], [1, 1]] # tf.rank(tensor) == 2
indices = [[0, 1], [2, 0]] # num_updates == 2, index_depth == 2
updates = [5, 10] # num_updates == 2
print(tf.tensor_scatter_nd_update(tensor, indices, updates))
tf.Tensor(
[[ 1 5]
[ 1 1]
[10 1]], shape=(3, 2), dtype=int32)
### Slice updates
When the input `tensor` has more than one axis scatter can be used to update
entire slices.
In this case it's helpful to think of the input `tensor` as being a two level
array-of-arrays. The shape of this two level array is split into the
`outer_shape` and the `inner_shape`.
`indices` indexes into the outer level of the input tensor (`outer_shape`).
and replaces the sub-array at that location with the corresponding item from
the `updates` list. The shape of each update is `inner_shape`.
When updating a list of slices the shape constraints are:
num_updates, index_depth = indices.shape.as_list()
outer_shape = tensor.shape[:index_depth]
inner_shape = tensor.shape[index_depth:]
assert updates.shape == [num_updates, inner_shape]
For example, to update rows of a `(6, 3)` `tensor`:
tensor = tf.zeros([6, 3], dtype=tf.int32)
Use an index depth of one.
indices = tf.constant([[2], [4]]) # num_updates == 2, index_depth == 1
num_updates, index_depth = indices.shape.as_list()
The `outer_shape` is `6`, the inner shape is `3`:
outer_shape = tensor.shape[:index_depth]
inner_shape = tensor.shape[index_depth:]
2 rows are being indexed so 2 `updates` must be supplied.
Each update must be shaped to match the `inner_shape`.
# num_updates == 2, inner_shape==3
updates = tf.constant([[1, 2, 3],
[4, 5, 6]])
#### Altogether this gives:
tf.tensor_scatter_nd_update(tensor, indices, updates).numpy()
array([[0, 0, 0],
[0, 0, 0],
[1, 2, 3],
[0, 0, 0],
[4, 5, 6],
[0, 0, 0]], dtype=int32)
#### More slice update examples
A tensor representing a batch of uniformly sized video clips naturally has 5
axes: `[batch_size, time, width, height, channels]`.
#### For example:
batch_size, time, width, height, channels = 13,11,7,5,3
video_batch = tf.zeros([batch_size, time, width, height, channels])
To replace a selection of video clips:
- Use an `index_depth` of 1 (indexing the `outer_shape`: `[batch_size]`)
- Provide updates each with a shape matching the `inner_shape`: `[time, width, height, channels]`.
To replace the first two clips with ones:
indices = [[0],[1]]
new_clips = tf.ones([2, time, width, height, channels])
tf.tensor_scatter_nd_update(video_batch, indices, new_clips)
To replace a selection of frames in the videos:
- `indices` must have an `index_depth` of 2 for the `outer_shape`: `[batch_size, time]`.
- `updates` must be shaped like a list of images. Each update must have a shape, matching the `inner_shape`: `[width, height, channels]`.
To replace the first frame of the first three video clips:
indices = [[0, 0], [1, 0], [2, 0]] # num_updates=3, index_depth=2
new_images = tf.ones([
# num_updates=3, inner_shape=(width, height, channels)
3, width, height, channels])
tf.tensor_scatter_nd_update(video_batch, indices, new_images)
### Folded indices
In simple cases it's convenient to think of `indices` and `updates` as
lists, but this is not a strict requirement. Instead of a flat `num_updates`,
the `indices` and `updates` can be folded into a `batch_shape`. This
`batch_shape` is all axes of the `indices`, except for the innermost
`index_depth` axis.
index_depth = indices.shape[-1]
batch_shape = indices.shape[:-1]
> [!NOTE]
> **Note:** The one exception is that the `batch_shape` cannot be `[]`. You can't update a single index by passing indices with shape `[index_depth]`.
`updates` must have a matching `batch_shape` (the axes before `inner_shape`).
assert updates.shape == batch_shape + inner_shape
> [!NOTE]
> **Note:** The result is equivalent to flattening the `batch_shape` axes of `indices` and `updates`. This generalization just avoids the need for reshapes when it is more natural to construct "folded" indices and updates.
With this generalization the full shape constraints are:
assert tf.rank(indices) >= 2
index_depth = indices.shape[-1]
batch_shape = indices.shape[:-1]
assert index_depth <= tf.rank(tensor)
outer_shape = tensor.shape[:index_depth]
inner_shape = tensor.shape[index_depth:]
assert updates.shape == batch_shape + inner_shape
For example, to draw an `X` on a `(5,5)` matrix start with these indices:
tensor = tf.zeros([5,5])
indices = tf.constant([
[[0,0],
[1,1],
[2,2],
[3,3],
[4,4]],
[[0,4],
[1,3],
[2,2],
[3,1],
[4,0]],
])
indices.shape.as_list() # batch_shape == [2, 5], index_depth == 2
[2, 5, 2]
Here the `indices` do not have a shape of `[num_updates, index_depth]`, but a
shape of `batch_shape+[index_depth]`.
Since the `index_depth` is equal to the rank of `tensor`:
- `outer_shape` is `(5,5)`
- `inner_shape` is `()` - each update is scalar
- `updates.shape` is `batch_shape + inner_shape == (5,2) + ()`
updates = [
[1,1,1,1,1],
[1,1,1,1,1],
]
Putting this together gives:
tf.tensor_scatter_nd_update(tensor, indices, updates).numpy()
array([[1., 0., 0., 0., 1.],
[0., 1., 0., 1., 0.],
[0., 0., 1., 0., 0.],
[0., 1., 0., 1., 0.],
[1., 0., 0., 0., 1.]], dtype=float32)
| ## Args ||
|---|---|
| `tensor` | Tensor to copy/update. |
| `indices` | Indices to update. |
| `updates` | Updates to apply at the indices. |
| `name` | Optional name for the operation. |
| ## Returns ||
|---|---|
| A new tensor with the given shape and updates applied according to the indices. ||